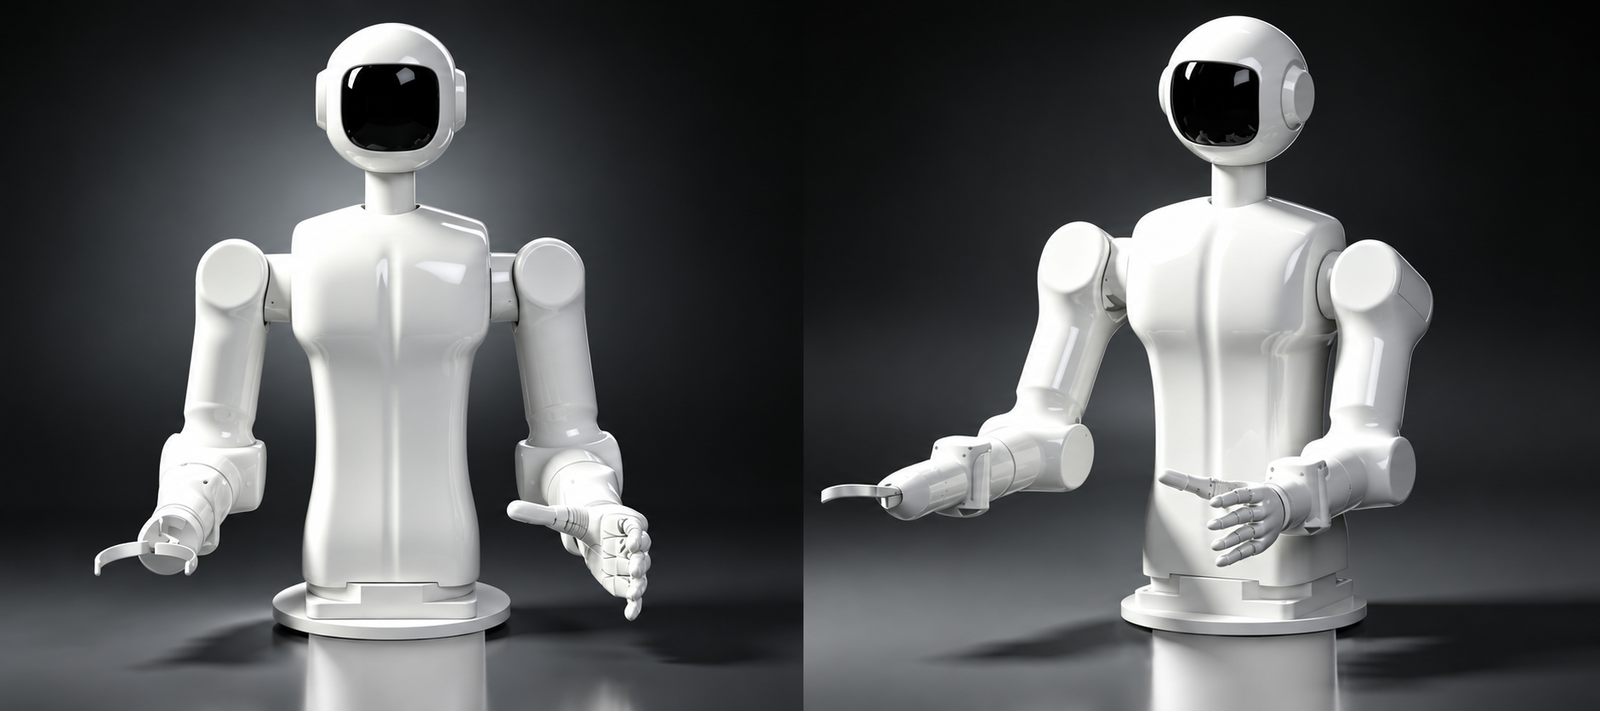
7-Axis Humanoid Dual-Arm Robot
A 14-degree-of-freedom dual-arm platform for robotics research and training, combining force control, open-source ROS development and modular expansion.
Built for research.
Ready to teach.
Designed for university teaching and embodied AI research in robotics engineering, artificial intelligence, automation and smart manufacturing. Each arm has seven axes, giving the platform 14 degrees of freedom. Redundant kinematics supports human-like upper-limb poses, while force control enables compliant interaction. Develop bimanual handling, assembly, screwdriving, sorting and material docking workflows through an open-source ROS development platform.
Discuss your curriculum, research objectives and integration needs with LINFENG to define a suitable platform configuration.
What this product
is built to deliver.
7 axes per arm · 14 DOF
Redundant kinematics supports human-like upper-limb poses and coordinated two-arm tasks.
Compliant force control
Force-control modules support compliant human-robot interaction for research and training. Application-specific safety measures are required.
Open-source ROS development
A research-friendly development platform for robotics coursework, motion-control experiments and embodied AI projects.
Modular expansion
A modular architecture supports extensions and upgrades as teaching and research requirements evolve.
Platform and application views.
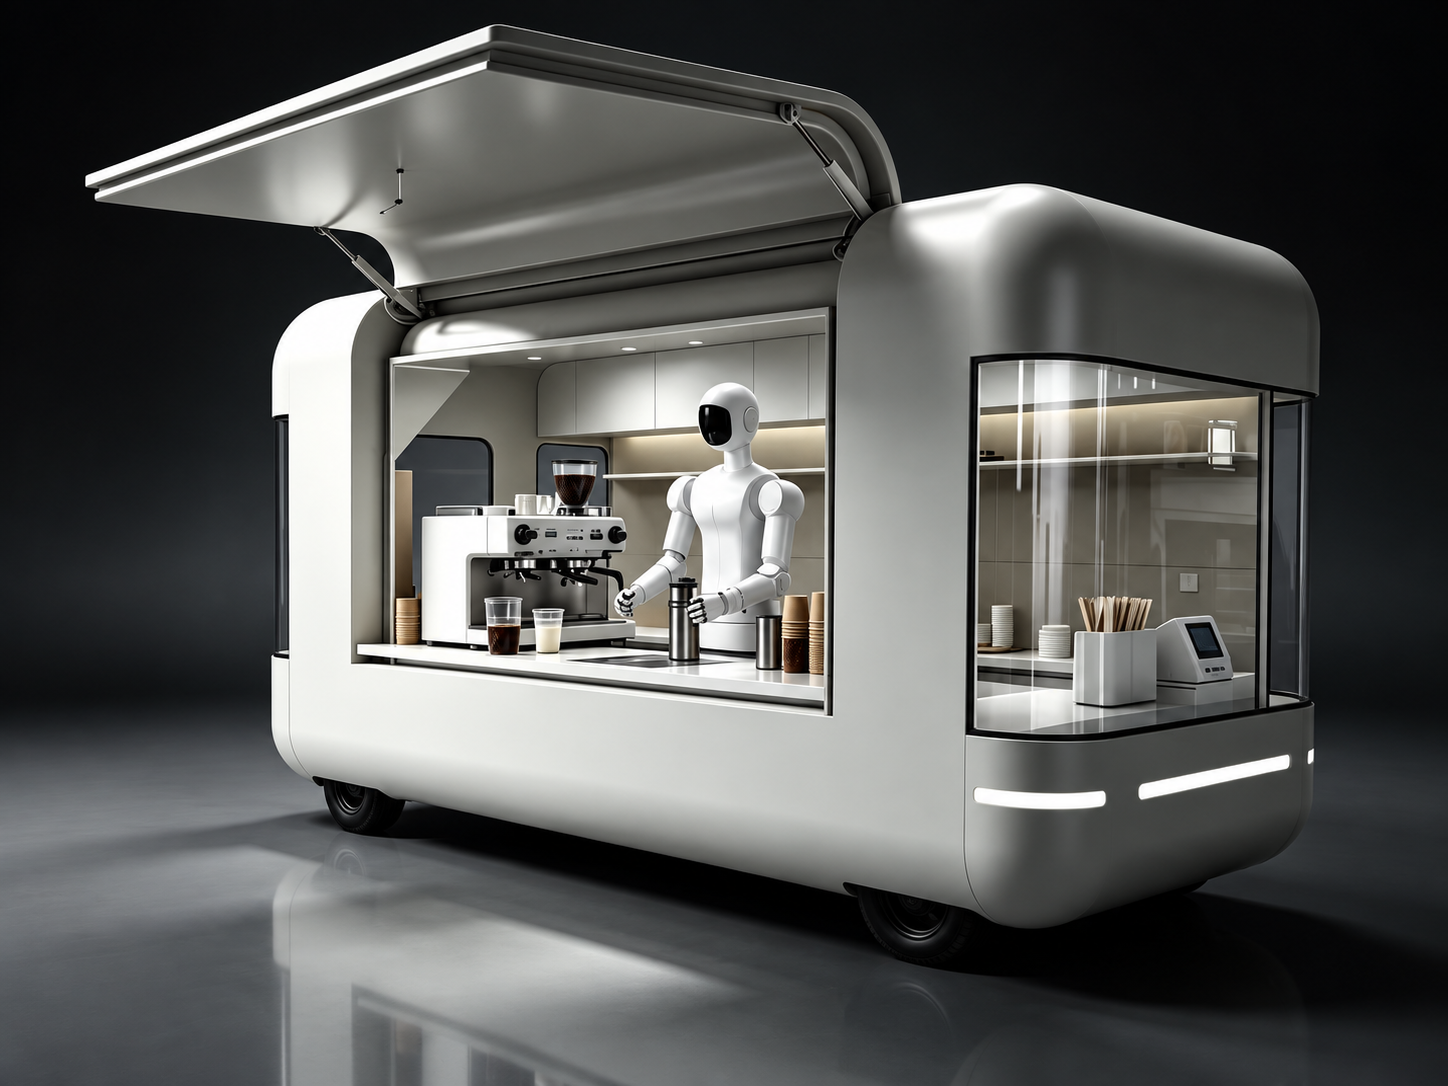
Visuals illustrate robot configurations and a coffee-service application. Final equipment and accessories depend on the selected configuration.
Tell us what the robot
needs to do.
Share your teaching objectives, research tasks and lab requirements. Our engineering team will help define the configuration.
Talk to an engineer