Mobile Manipulator
An AGV-mounted robotic arm combining mobile transport, vision positioning and automated handling.
Designed around
real production.
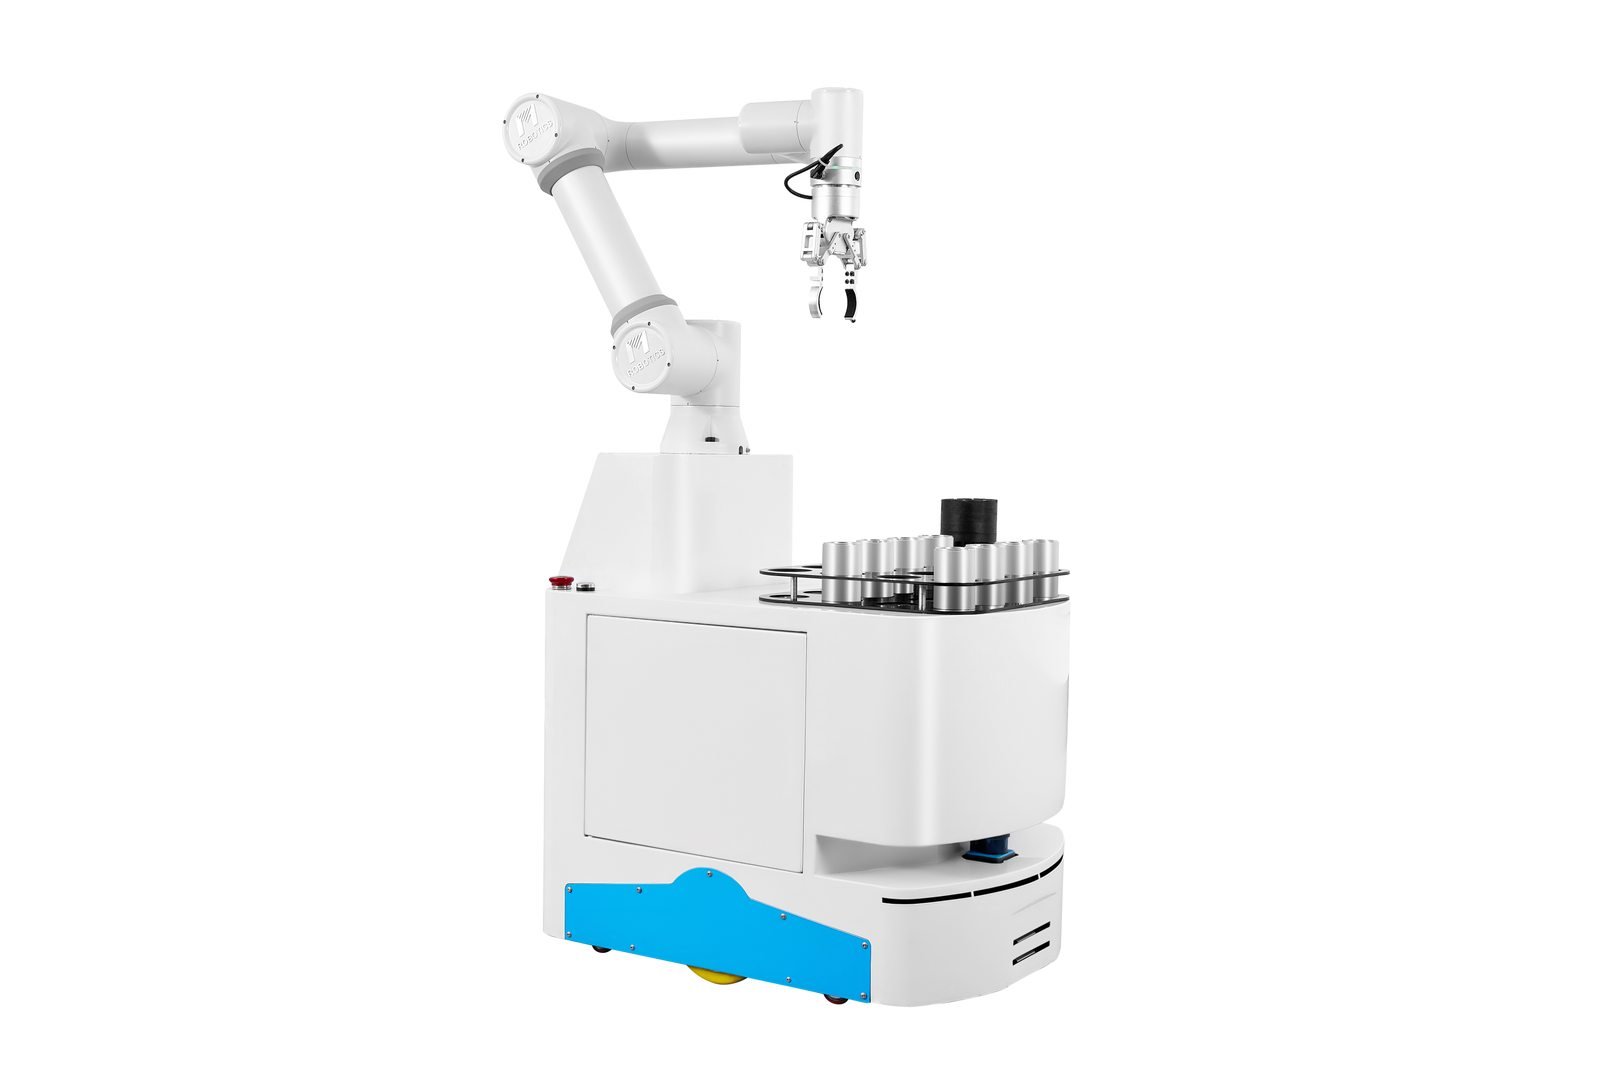
The mobile manipulator combines an AGV base, robotic arm, vision system and end effector for material handling and assembly. Navigation brings the robot to the working area, while vision-based secondary positioning supports alignment for the task. The integrated platform connects mobile transport with robotic manipulation.
LINFENG can adapt this automation system to your process, workspace, tooling and production target. Share your application details for a configuration review.
What this product
is built to deliver.
Transport and handling
A mobile base and robotic arm combine material movement with manipulation.
Vision positioning
Vision-based secondary positioning helps align the robot with its working target.
Flexible operation
Navigation and robot motion support automated handling across different working locations.
Tell us what the robot
needs to do.
Send your workpiece, cycle target and site requirements. Our engineering team will help shape the solution.
Talk to an engineer